Vaidehi Dalmia

I am a master's student at the University of Southern California, where I do research in the SLURM Lab, advised by Dr. Daniel Seita. I work on robot manipulation with foundation models, and I am especially interested in training policies that stay robust in cluttered, real-world environments. Before USC, I studied at Columbia University.

I like building the whole stack: environments, data pipelines, training, and evaluation on real robots and in simulation.

Vaidehi Dalmia

Research

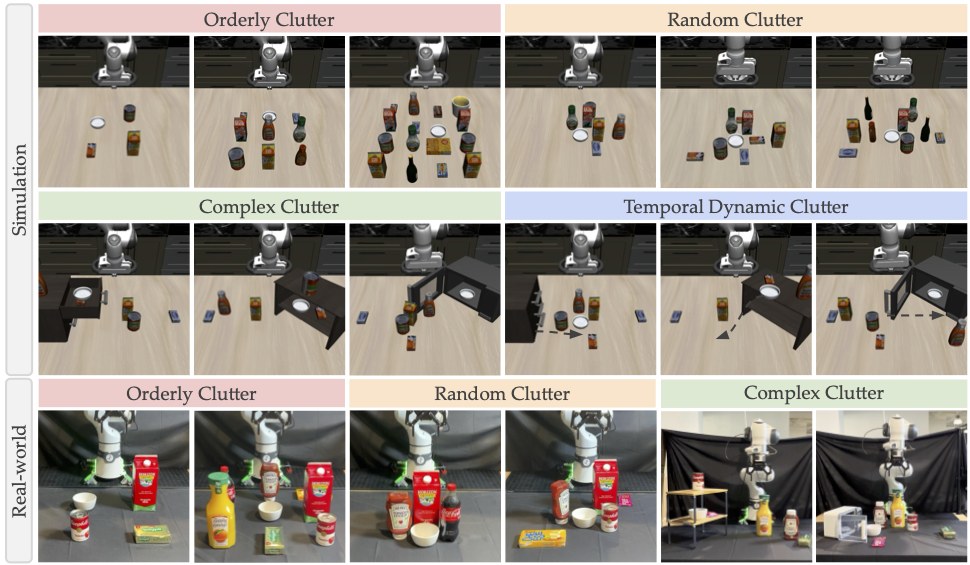
ClutterBench overview: simulated and real-world cluttered scenes with a robot arm

ClutterBench: A Benchmark for Evaluating Vision-Language-Action Models in Cluttered Environments

Yuxuan Li*, Juneyoung Yoon*, Vaidehi Dalmia*, Yiyang Ling, Ue-Hwan Kim, Daniel Seita (* equal contribution)

NeurIPS 2026 Workshop on Vision Language Models: Challenges of Real-World Deployment (VLM4RWD)

A benchmark for testing VLA policies on manipulation in cluttered scenes, spanning four kinds of clutter, evaluated across seven models in simulation and three on a real robot. Beyond success rate, it measures how much the policy disturbs objects it was not asked to move.
in progress

Ongoing work on VLA policies for manipulation in progress

A follow-up to ClutterBench that looks at physical clutter: scenes where the environment itself gets in the way of the arm, not just the objects on the table. Details to come once the work is ready to share.

Education

University of Southern California

M.S.

Columbia University

B.S.

Contact

The best way to reach me is by email: vaidehidalmia@gmail.com. I am always happy to talk about robot learning, manipulation, or the lab.